Dexterous Hands
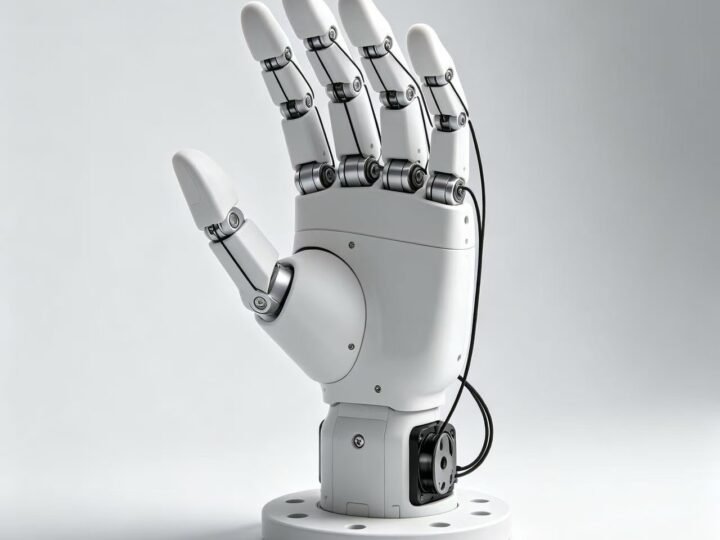
Dexterous Hand — Tendon-Driven
Superelastic tendon transmission · Proximal motor layout · Ultra-lightweight fingers · For high-envelope anthropomorphic grasp / confined-space manipulation
View DetailsMotion, drive and interaction components for advanced robotics.
Superelastic tendon transmission · Proximal motor layout · Ultra-lightweight fingers · For high-envelope anthropomorphic grasp / confined-space manipulation
View Details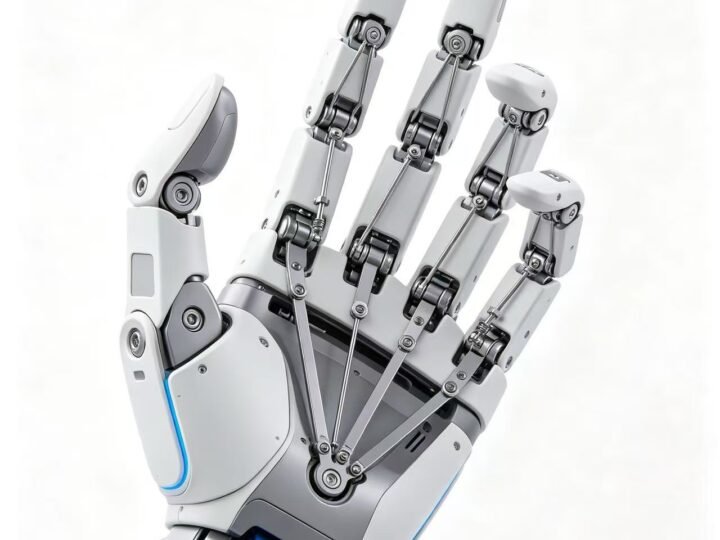
Full metal linkage transmission · Zero elastic backlash · High stiffness output · For industrial precision assembly / force-controlled screwing / high-cycle production
View Details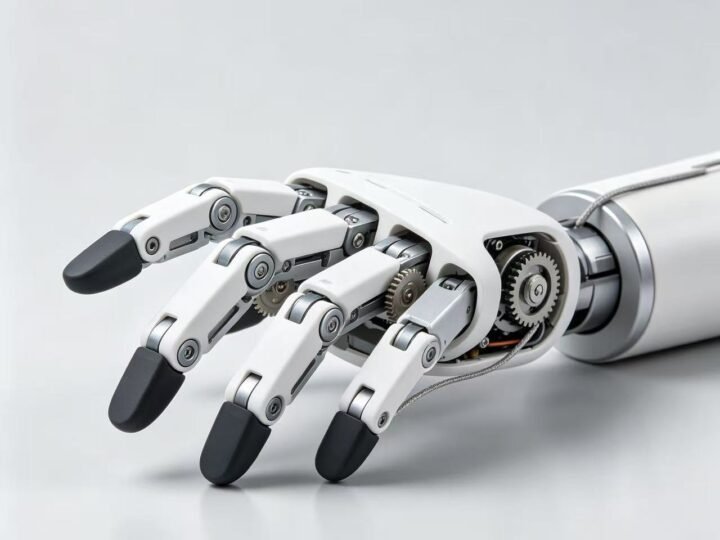
Multi-transmission fusion · Rigid-flex complementarity · Balances payload & dexterity · For premium humanoid actuators / complex assembly
View Details
Gearless micro-motor direct drive · Zero-backlash force control · Joint-level torque sensing · For compliant manipulation / safe HRI / research platforms
View Details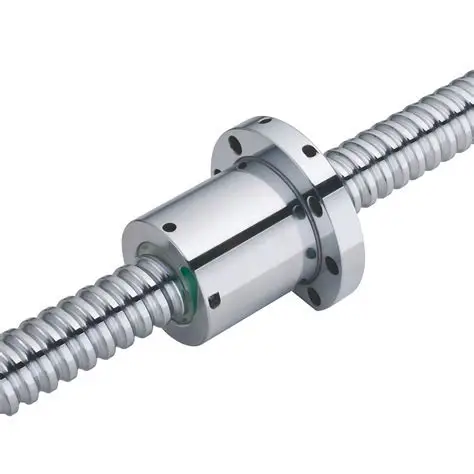
Precision ground raceways · High positioning accuracy · Low backlash · For robotic linear joints / lift modules
View Details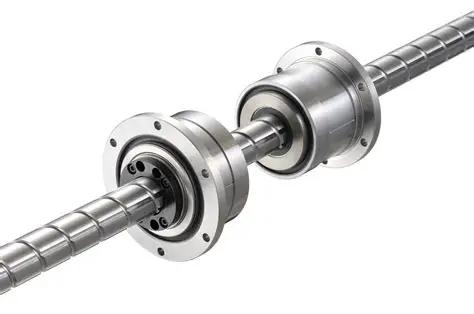
Combined rotary + linear transmission · High torque transfer · Zero-backlash preload options · For robotic Z-axis / wrist rotary-lift
View Details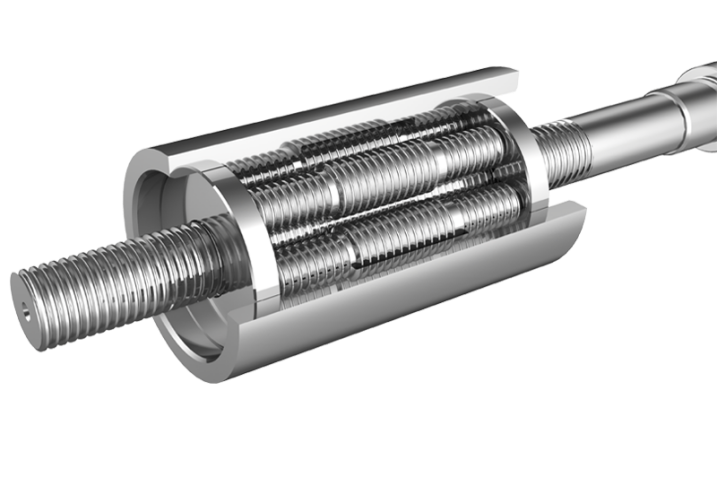
Full-thread roller meshing · Ultra-high thrust-to-weight · Impact-resistant / non-backdrivable · For humanoid linear actuators / leg joints
View Details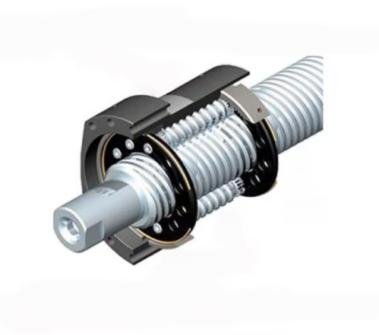
Miniaturized thread raceway · High thrust density in compact space · Low friction · For anthropomorphic dexterous hand finger drives
View Details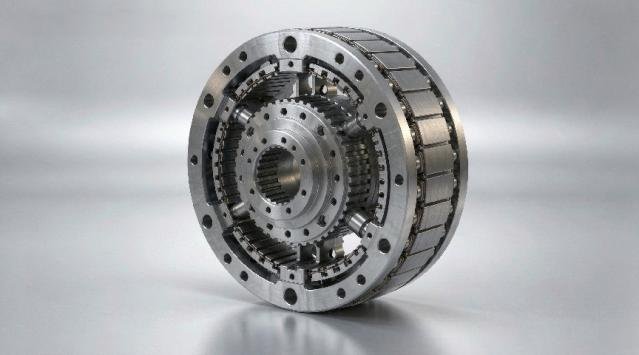
· Slotless stator + rare-earth rotor · Modular cable exit · For direct-drive humanoid joints / cobot arm axes / surgical manipulators
View Details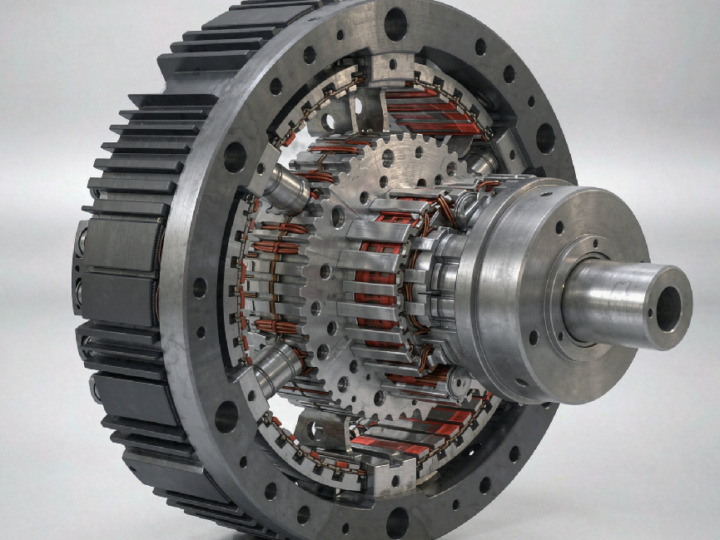
· Large-diameter flat topology · High torque density · For humanoid hip/knee joints (QDD) / quadruped leg drives / wheel hub direct-drive
View Details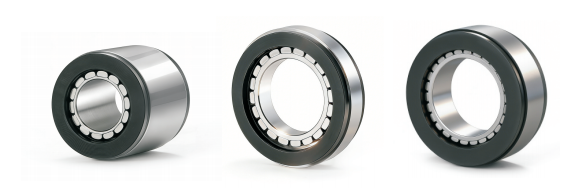
· Frameless torque motor + inverted planetary roller screw · High thrust density · Coaxial integration · For humanoid hip/knee/ankle pitch & roll /…
View Details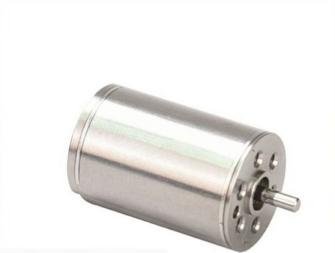
· Coreless cup rotor with self-supporting skewed winding· Zero cogging · Ultra-smooth rotation · Low inertia · Fast acceleration and response· For robotic finger…
View DetailsShare your drawing, specification or target application and our engineering team will source the right solution.
Request a Quote